

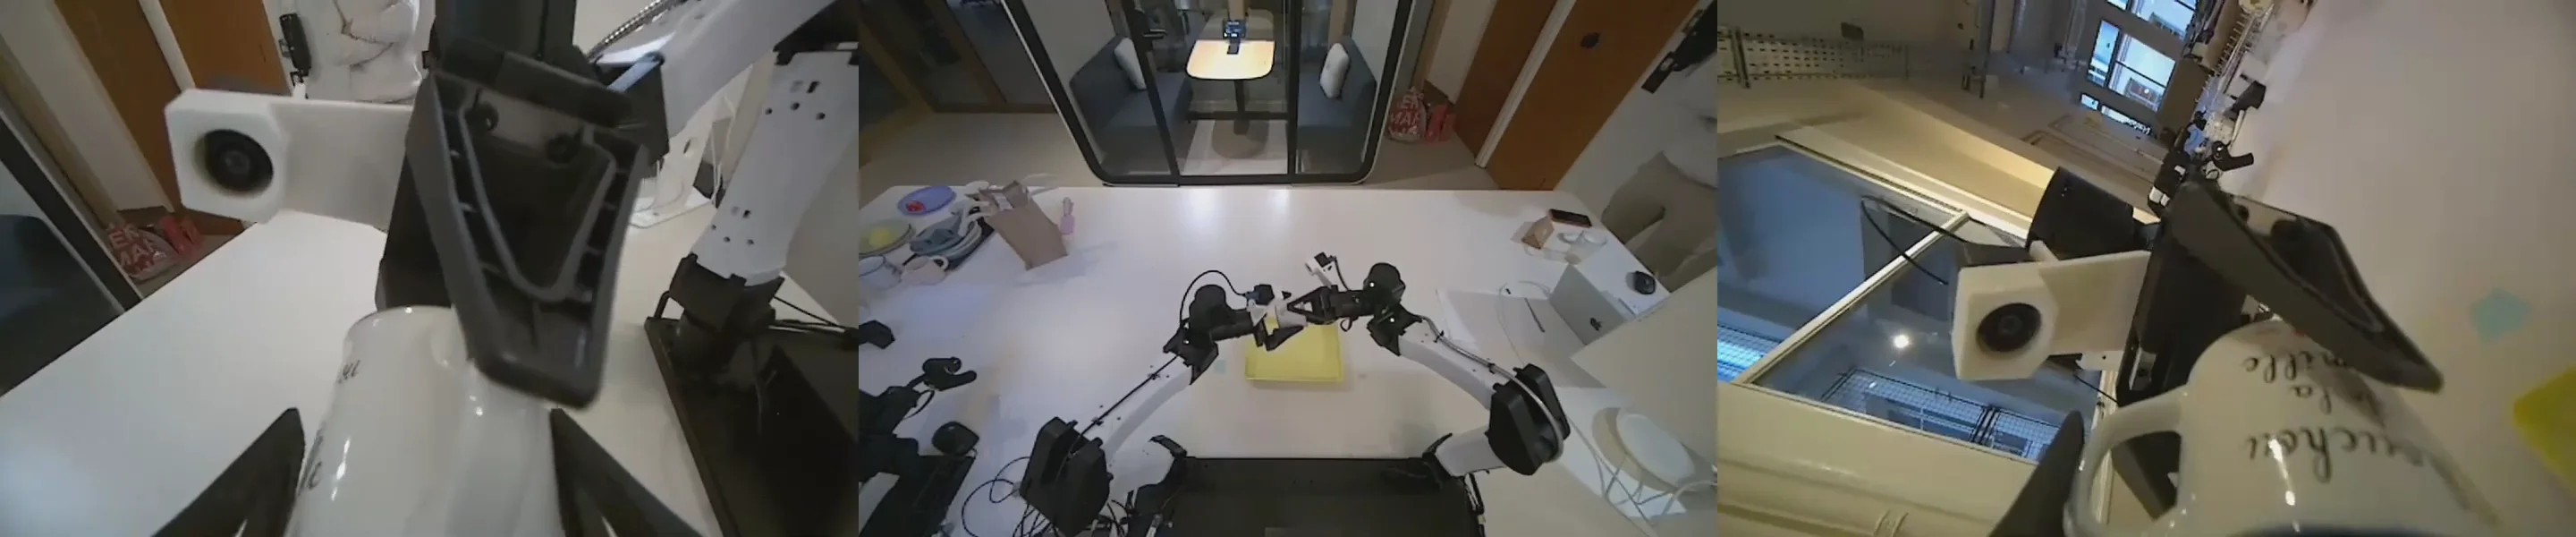
Praxis-1 is now available
Runway Praxis-1
An open weight world action model that turns Runway’s video pretraining into control for real robots.
Praxis-1
Run and adapt it on your own hardware.
Praxis-1 learns how objects behave and how tasks unfold from large-scale video, which gives it a head start on a new embodiment before fine-tuning on any hardware or domain-specific data. Give it camera observations, your robot's state and a task, and it predicts the actions to carry it out.
Open weights, Apache 2.0
Weights on Hugging Face, with inference and fine-tuning code on GitHub. Licensed for commercial use.
Adapt it to your hardware
A single Praxis-1 checkpoint adapts to new embodiments with fine-tuning.
Runs where you build
Available in LeRobot and vLLM-Omni, with hosted inference on Reactor.
Read more
Company News
Praxis-1 Is Now Available
Praxis-1, Runway’s world action model for robotics, is now available with open weights under Apache 2.0. Download it on Hugging Face and GitHub.
Research
Introducing Praxis-1
An open-weight world action model that turns Runway's video pretraining into control for real robots.
Research
Praxis-1: From Video Pretraining to Robot Control
How Praxis-1 is built, how we train it and how it scales.
